Victor Dhédin
About Me
I’m a PhD candidate at the Technical University of Munich (TUM), advised by Prof. Majid Khadiv, with a background in machine learning and robotics. My research focuses on solving loco-manipulation tasks with a humanoid robot.
Before that, I received my Master’s degree in Data and Information Sciences from CentraleSupélec, and spent time at the Max Planck Institute for Intelligent Systems, the French Atomic Energy Commission (CEA) and Thales.
I'm exploring a potential transition from academia to industry. Feel free to reach out.
Research Interests
- Humanoid Loco-Manipulation: whole-body skills in constrained environments.
- Synthetic Data Generation: dynamically-feasible motion retargeting and trajectory optimization.
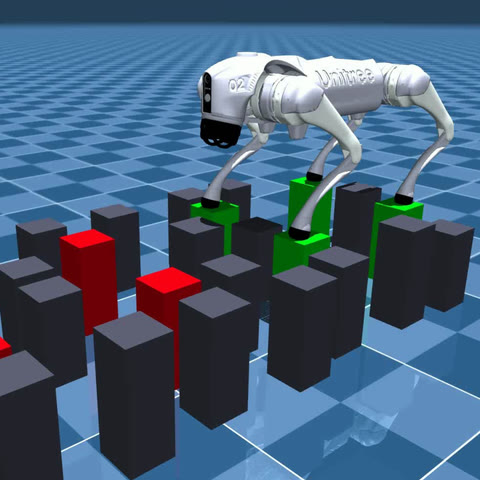
- Contact Planning: learning-based and sampling-based planning for dynamic legged locomotion.
News
- [2026] 📜 Two papers accepted to IEEE Robotics and Automation Letters (RA-L): DynaRetarget and Humanoid-DART.
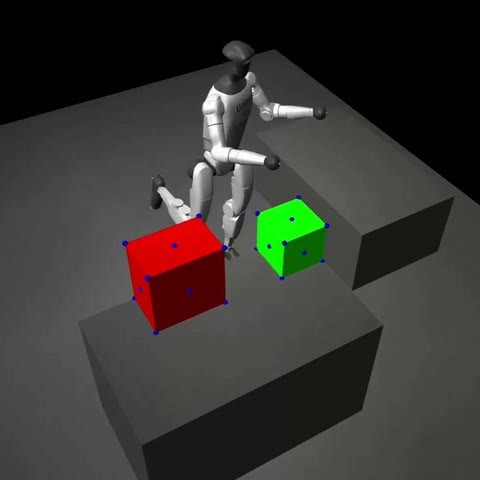
- [Aug. 2025] 📜 Two papers accepted at Humanoids 2025: Simultaneous Contact Sequence and Patch Planning for Dynamic Locomotion and TAMP for humanoid loco-manipulation.
Education
- Ph.D. Candidate, Technical University of Munich, Germany, 2023–present.
Thesis: Learning loco-manipulation skills in constrained environments.
Advisor: Prof. Majid Khadiv. - Master’s in Data and Information Sciences, CentraleSupélec, Paris, France, 2019–2023.
GPA: 4.0/4.0. Statistics, Computer Science, Robotics.
Publications
* equal contribution † project lead ‡ corresponding author
|
-
IEEE Robotics and Automation Letters (RA-L), 2026.
-
IEEE Robotics and Automation Letters (RA-L), 2026.
-
IEEE-RAS International Conference on Humanoid Robots (Humanoids), 2025.
-
IEEE-RAS International Conference on Humanoid Robots (Humanoids), 2024.
-
IEEE International Conference on Robotics and Automation (ICRA), 2023.
-
IEEE Robotics and Automation Letters (RA-L), 2026.
-
IEEE Robotics and Automation Letters (RA-L), 2026.
-
IEEE-RAS International Conference on Humanoid Robots (Humanoids), 2025.
-
 IEEE-RAS International Conference on Humanoid Robots (Humanoids), 2025.
-
IEEE-RAS International Conference on Humanoid Robots (Humanoids), 2024.
-
 Learning for Dynamics and Control Conference (L4DC), 2024.
-
IEEE International Conference on Robotics and Automation (ICRA), 2023.
Software
-
Official implementation of the sampling-based trajectory optimization behind DynaRetarget. It refines imperfect kinematic trajectories into dynamically feasible humanoid motions, incrementally extending the optimization horizon for long-horizon tasks.Language: Python, MuJoCo
-
Modular Nonlinear Model Predictive Control (NMPC) framework for quadruped robots, built on the Acados solver and Pinocchio. Easily adapted to new robots through URDF, gait and controller configuration.Language: Python, Acados, Pinocchio


Experience
Academic Experience
-
PhD Candidate: 2023 – Present.Topics: Humanoid Loco-Manipulation, Synthetic Data Generation, Trajectory Optimization, Contact Planning.
Advisor: Prof. Majid Khadiv. -
Research Assistant: Jan. – Jun. 2022.Integrated a Visual-Inertial Odometry (VIO) algorithm on a Solo12 quadruped robot, with extensive real-world indoor and outdoor experiments. Published at ICRA 2023.
Industry Experience
-
Research Intern: May – Nov. 2023.Master Thesis: Parametrization of robotic actions through demonstrations (graded A+, 20/20).
Developed a graphical interface for novice users to program robotic arms for assembly tasks via kinesthetic demonstrations, with real-robot experiments and a user study. Led to a publication in Fusion Engineering and Design 2025. -
Research Engineer Intern: Jun. – Dec. 2021.Developed a proof-of-concept deep learning method for reconstructing corrupted audio recordings. Recorded and processed terabytes of audio data from an experimental optical-fiber distributed acoustic sensor (DAS).
Academic Service
Teaching
- [2025] Scientific Seminar: Learning-based Legged Locomotion.
- [2025] Foundations of Modern Robotics (Teaching Assistant).
Reviewer
- [2026] TRO, RSS, ICRA, IROS.
- [2025] TRO, RA-L, CoRL.
Powered by Jekyll and Minimal Light theme.